experiments

End effectors · source study

What do the latest hands actually do?

This index puts recent company releases beside the official photos and videos that support them. It is source material for the Unhandy Valley, not an independent performance benchmark.

Current public evidence

Dates refer to the cited company publication. Product specifications and performance statements remain attributed to each publisher.

01 Capability release

Sunday Robotics

Memo

ACT-2 Preview: Generalizing Reliability

Sunday’s latest preview puts Memo’s paired three-finger hands through garment retrieval, regrasping, folding, and stacking in homes outside its training set.

Published
Evidence
Uncut task trials
  • Paired three-finger end effectors.
  • The release focuses on deformable-object handling.
  • Sunday reports 99.1% zero-shot laundry-fold success.
Memo using both three-finger hands to manipulate a garment.
Official image Memo folding a garment. Company-hosted release image.
Official video ACT-2 Preview ↗

02 Product release

1X

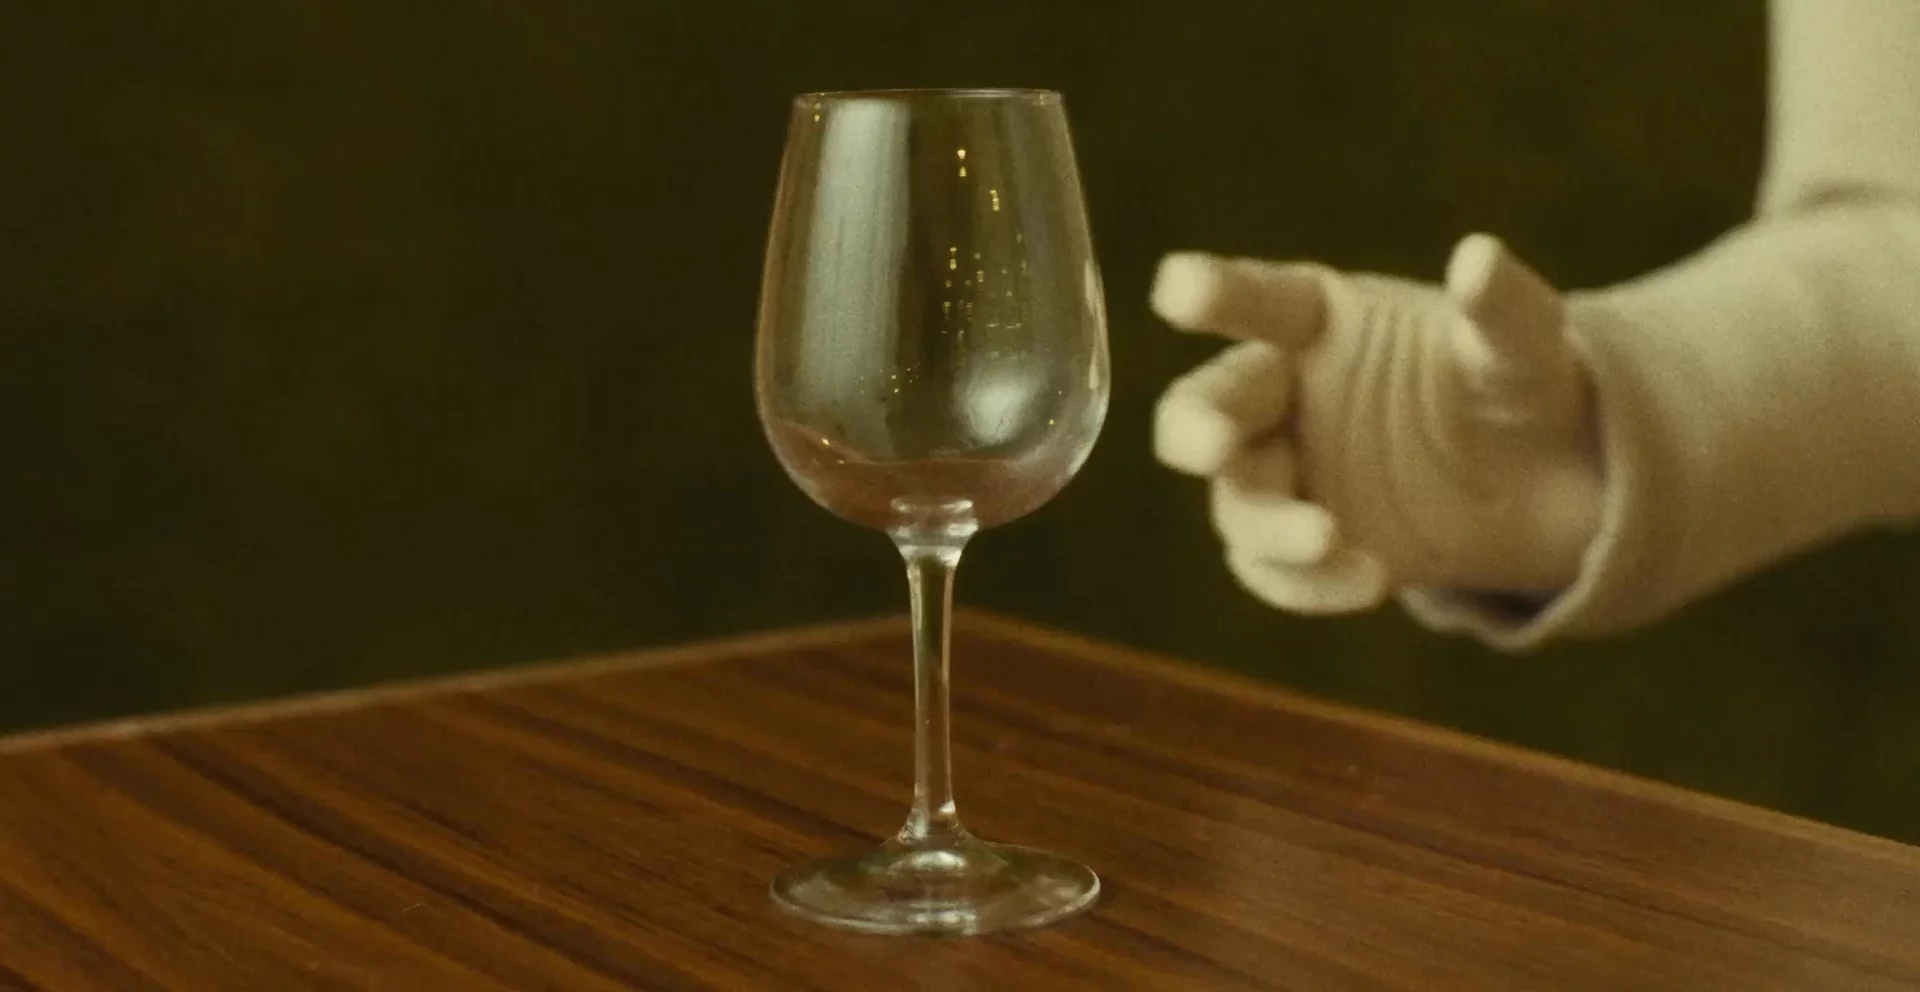
NEO hands

NEO’s Hands: An API to the Physical World

1X presents a new tendon-driven hand for NEO. The release emphasizes force control, backdrivability, tactile skin, and fine contact tasks.

Published
Evidence
Technical release
  • 25 degrees of freedom across the hand and wrist.
  • 22 fully actuated finger and palm degrees of freedom.
  • Tactile skin measures pressure, contact location, and slip.
A NEO robot hand reaching toward the stem of a wine glass.
Official image Courtesy of 1X. Company-hosted release still.
Official video NEO’s Hands ↗

03 Platform release

PSYONIC

Ability Hand

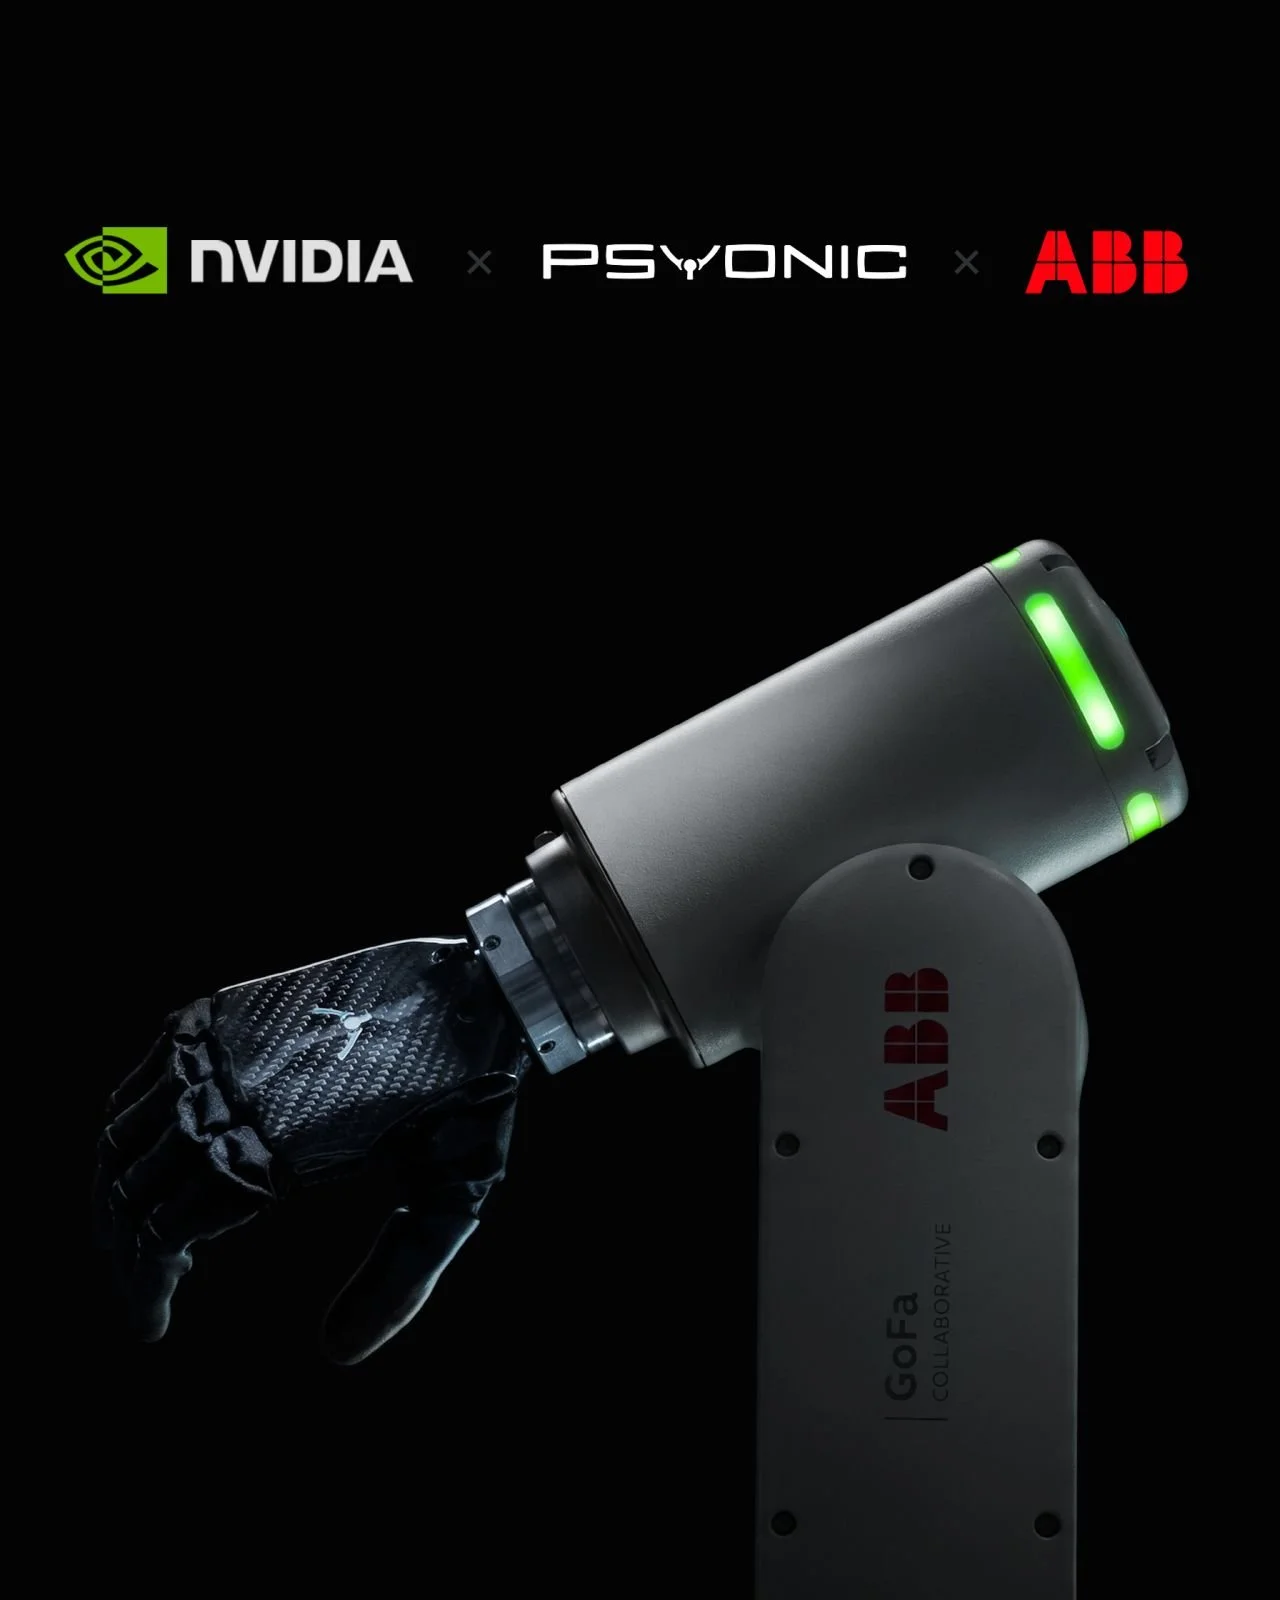
ABB Robotics partnership with supporting NVIDIA transfer demo

PSYONIC’s June 22 Automate 2026 release places the Ability Hand on an ABB GoFa arm. Its supporting NVIDIA release shows the same hand moving a pipetting task from a human user to several robot platforms. The page was posted July 6.

Published
Evidence
Integration + demo
  • The collaborators are exploring tactile sensing and compliant mechanics on an industrial arm.
  • The hand is available as a native asset in NVIDIA Isaac Lab.
  • The demonstration uses one hand design across human and robot platforms.
A PSYONIC Ability Hand mounted on an ABB GoFa collaborative robot.
Official image Ability Hand on ABB GoFa. Company-hosted release image.
Official video NVIDIA GTC real-to-real demonstration ↗

04 Platform release

Sharpa

Wave

Wave on the NVIDIA Isaac GR00T reference humanoid

Sharpa’s latest integration release mounts two human-scale Wave hands on NVIDIA’s reference humanoid. The product video gives a closer view of finger motion and contact manipulation.

Published
Evidence
Integration + demo
  • 22 active degrees of freedom in each five-finger hand.
  • Dynamic Tactile Array sensors in the fingertips.
  • Sharpa reports more than 1,000 tactile pixels per fingertip.
Two Sharpa Wave hands installed on the NVIDIA Isaac GR00T reference humanoid.
Official image Dual Wave integration. Company-hosted release image.
Official video SharpaWave product film ↗

05 Product release

Boston Dynamics

Atlas gripper

Product Atlas and its newest-generation hand

Boston Dynamics launched product Atlas at CES 2026 after publishing a focused explanation of its electric humanoid gripper. The design balances industrial load handling with delicate contact.

Published
Evidence
Product launch + explainer
  • Three fingers, including an opposable thumb.
  • Seven degrees of freedom in the gripper.
  • Tactile fingertips and cameras in the palm.
Close view of the three-finger electric Atlas gripper.
Official image Official video still. Linked to Boston Dynamics.
Official video What’s in a humanoid hand? ↗

06 Product release

TheRobotStudio · Hugging Face

SO-101 gripper

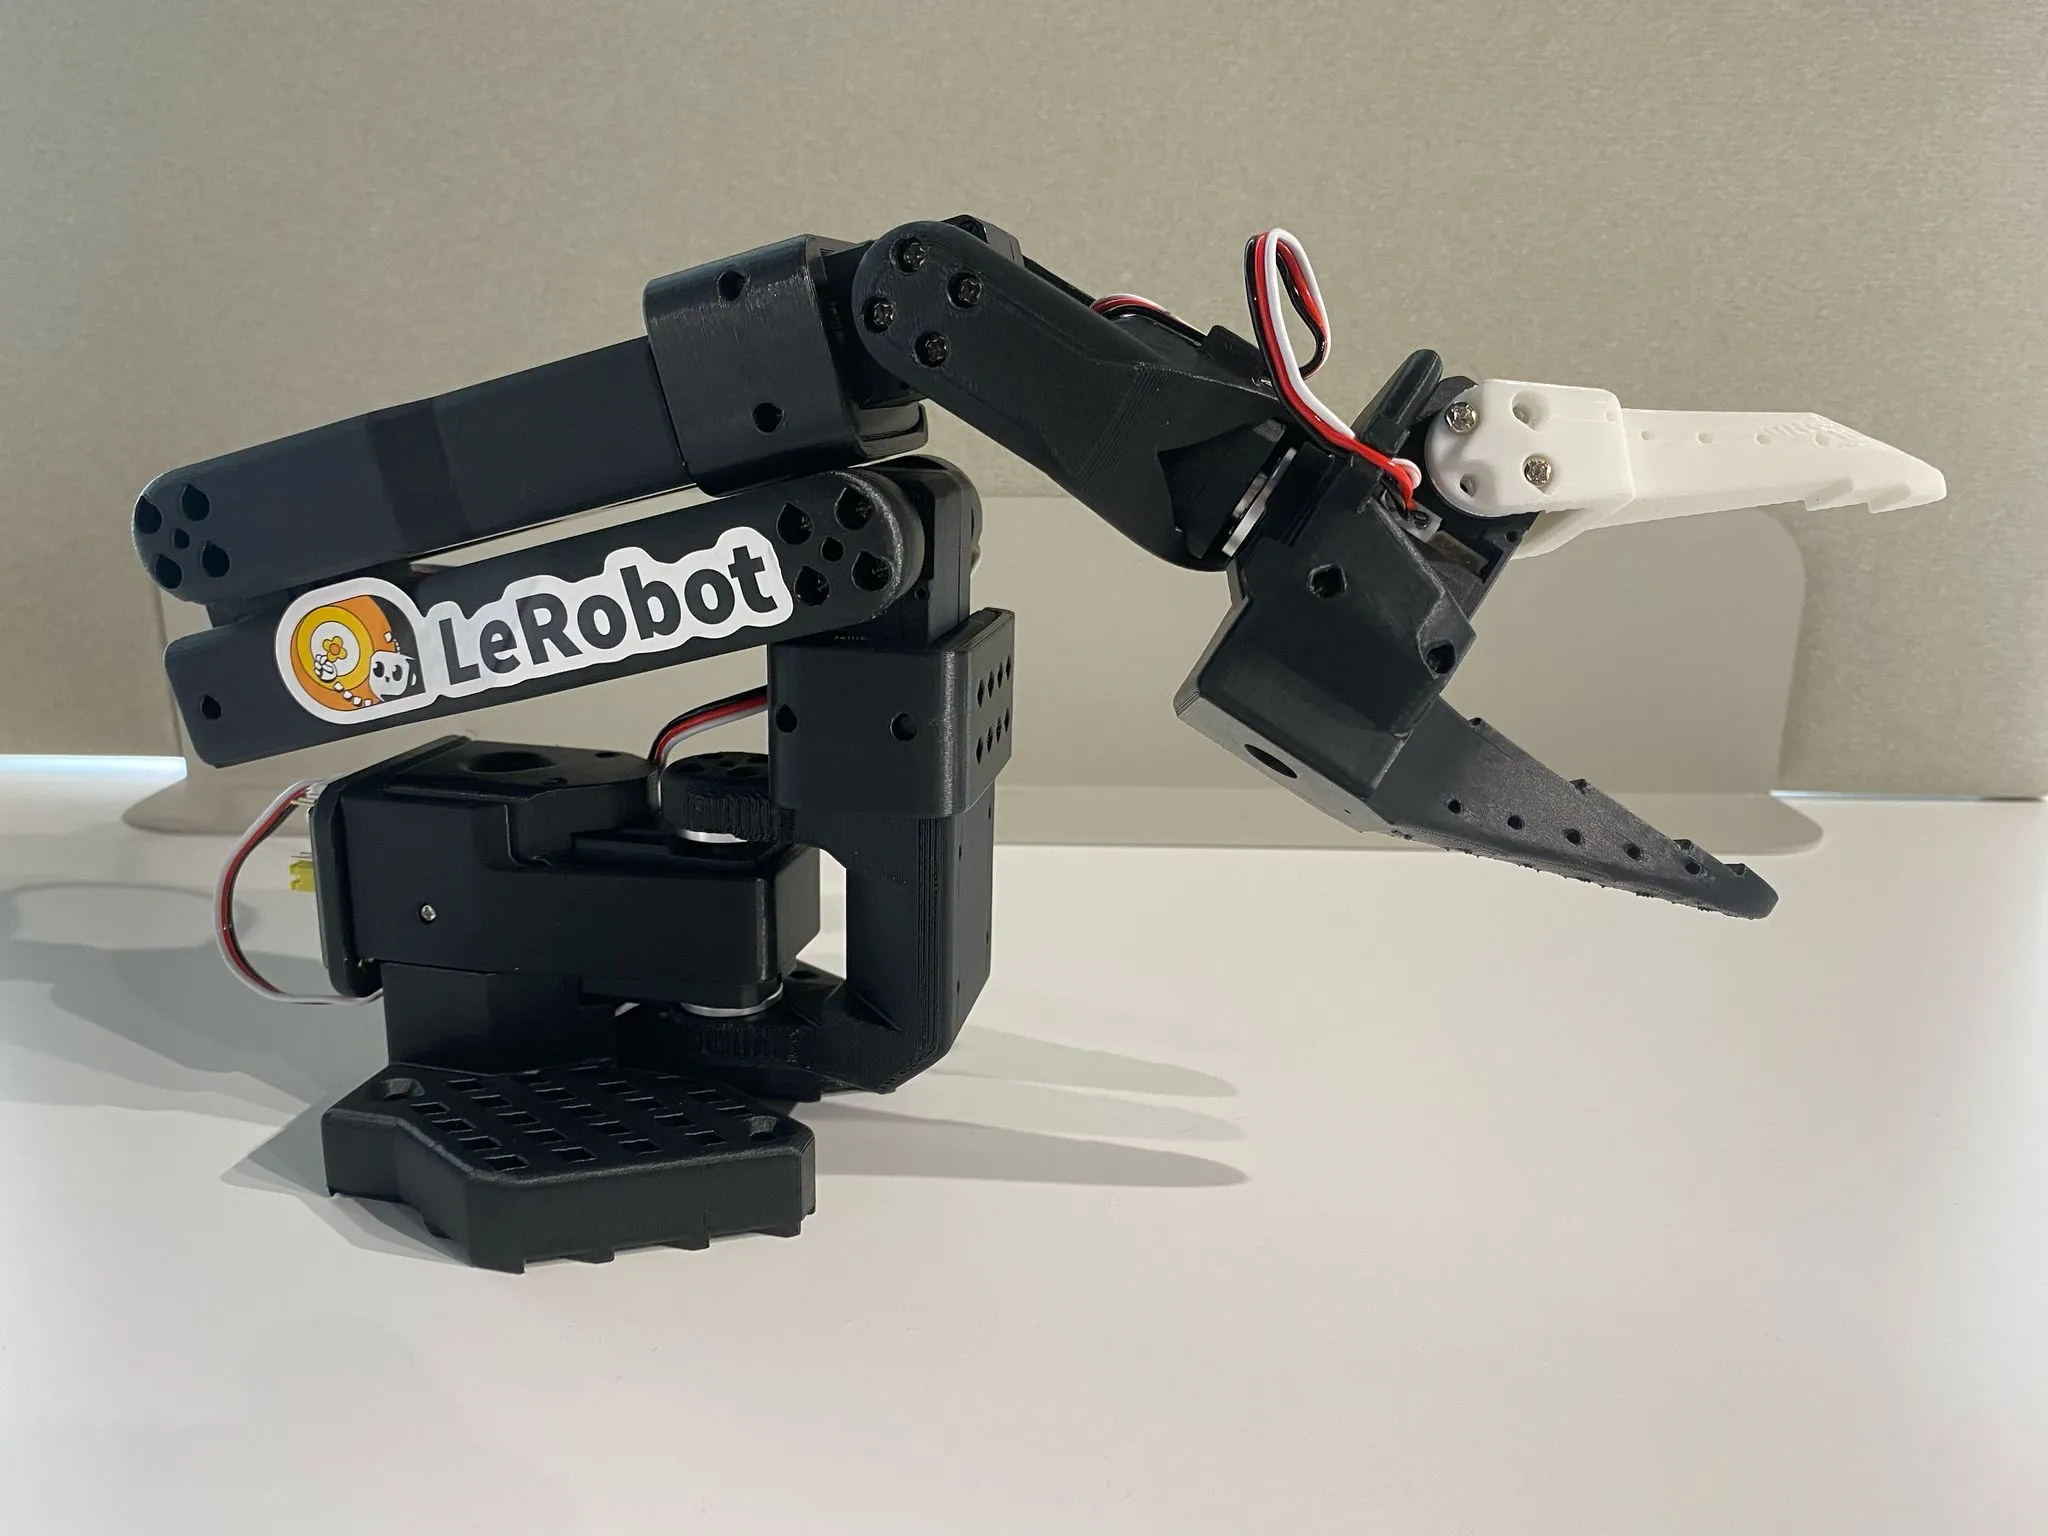
SO-101 open robot arm

The SO-101 follower arm ends in a servo-driven two-jaw gripper. Its leader arm uses a hand grip and trigger to collect demonstrations for the open LeRobot stack.

Published
Evidence
Open CAD + docs
  • Servo-driven parallel gripper on the follower arm.
  • Hand grip and trigger on the leader arm.
  • CAD, assembly files, and software are published openly.
The SO-101 follower robot arm with its two-jaw gripper.
Official image Pinned project image. Apache-2.0 repository.
Official video SO-101 setup motion ↗